AI Robotic Sorting Arm with Computer Vision
Raspberry Pi · Arduino · camera + AI · closed-loop conveyor
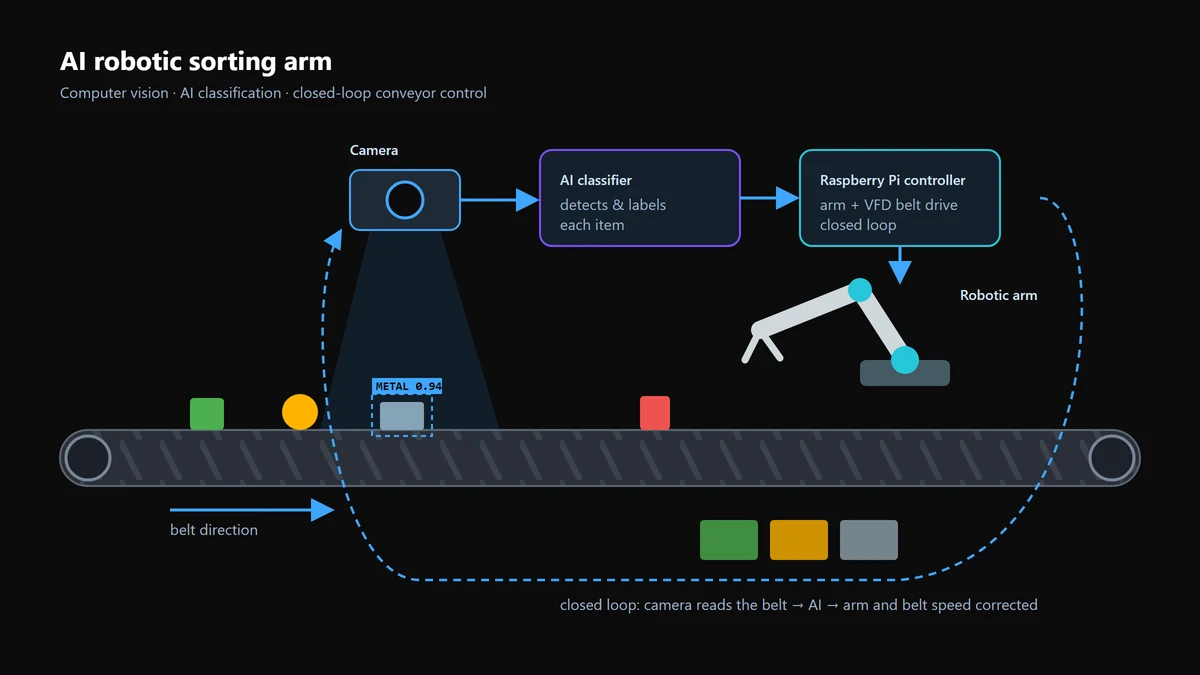
A robotic arm that sorts waste on a moving conveyor belt. Cameras read the belt, an AI model classifies each item, and the arm picks it and drops it in the right bin while the belt keeps running, all in a closed control loop. A Raspberry Pi runs the vision and the decisions; the low-power control side drives the high-power belt motor through optocouplers and a variable frequency drive.
Technologies
My role
Built it end to end: the vision and classification on the Raspberry Pi, the arm and conveyor control, and the low-to-high power stage with optocoupled outputs and the VFD.
Highlights
- Cameras detect each item on the belt and the AI classifies it
- The robotic arm picks and sorts items while the belt is moving
- Closed loop: what the camera sees corrects the arm and the belt speed
- Optocoupled outputs isolate the Raspberry Pi from the power side
- A variable frequency drive steps the control signal up to drive the belt motor